


Technical illustration of an autonomous vehicle parking system with sensor waves and overlaid labels.
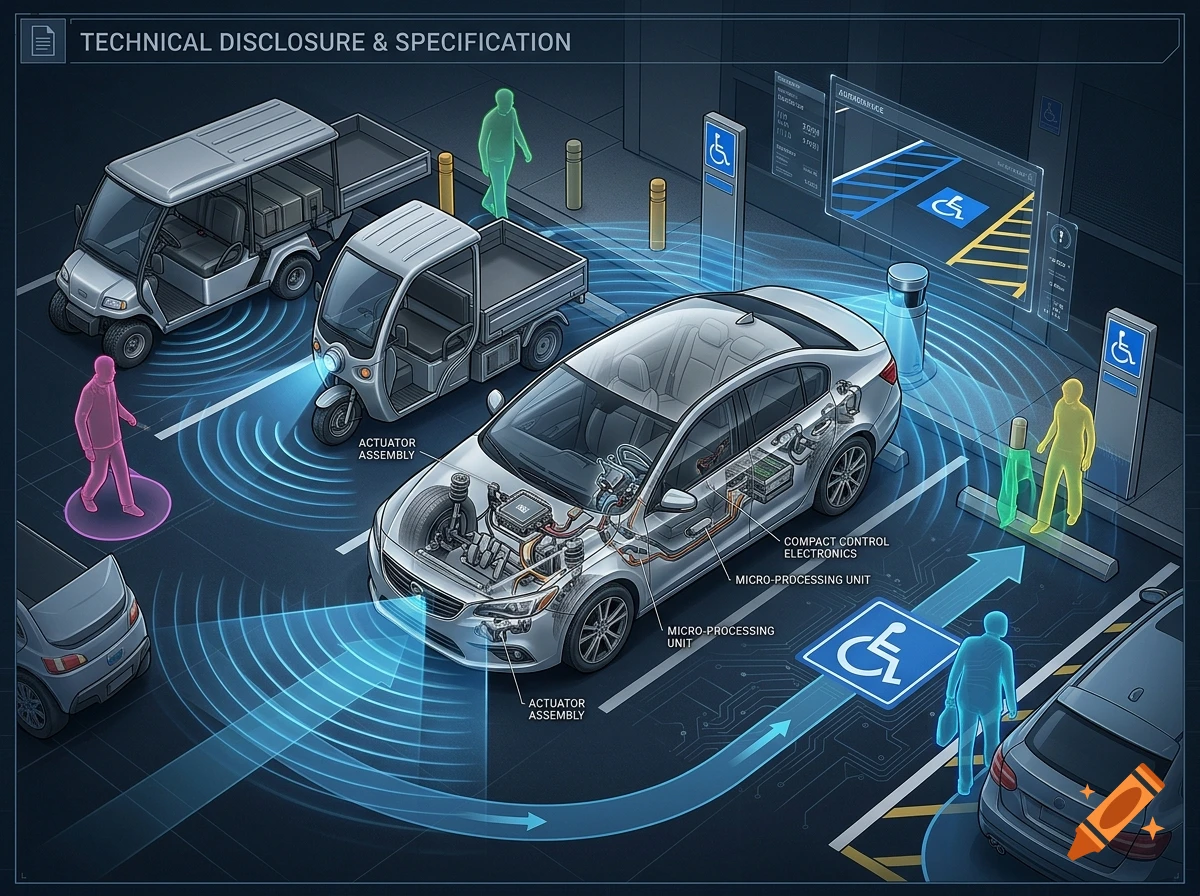
TECHNICAL DISCLOSURE & SPECIFICATION:The invention comprises an aftermarket electromechanical automation kit configured to interface with adaptive driving equipment on low-speed vehicles (LSVs), electric trikes, or standard consumer vehicles to execute short-range autonomous parking and retrieval sequences on private property at restricted velocities.Multi-Sensor Environmental Perception Array: The vehicle perimeter is monitored by a dual-platform array comprising high-definition digital peripheral cameras and an array of acoustic ultrasonic proximity sensors coupled with Light Detection and Ranging (LiDAR) scanners. The sensory architecture uses concurrent light-pulse reflection mapping and acoustic absorption frequency calculations to dynamically categorize surrounding obstacles by density and shape, distinguishing moving human pedestrians from inanimate parking lot structures.Chrominance and Pattern-Matching Parking Logic: An internal central micro-processing unit runs computer-vision convolutional filters configured to identify designated accessible parking stalls. The perception loop utilizes chrominance thresholding to isolate blue pavement paint configurations from standard white/yellow road lines, combined with geometric matrix pattern-matching to verify the International Symbol of Access (wheelchair emblem) and vertical signage pillars before executing a vector path trajectory.Mechanical Adaptive Actuator Interface: The actuation assembly consists of modular, Voir plus
More images like this


